
🤖 About me
Hi there 👋, I am Zirui Wang (王子瑞).
I’m currently a Ph.D student at The Hong Kong University of Science and Technology (Guangzhou), jointly supervised by Prof. Boyu Zhou, Prof. Jun Ma, and Prof. Jian Guo. Prior to that, I earned my Bachelor’s and Master’s degrees at Southern University of Science and Technology (SUSTech) under the supervision of Prof. I-Ming Chen and Prof. Jing Wu.
📝 Publications
*equal contribution
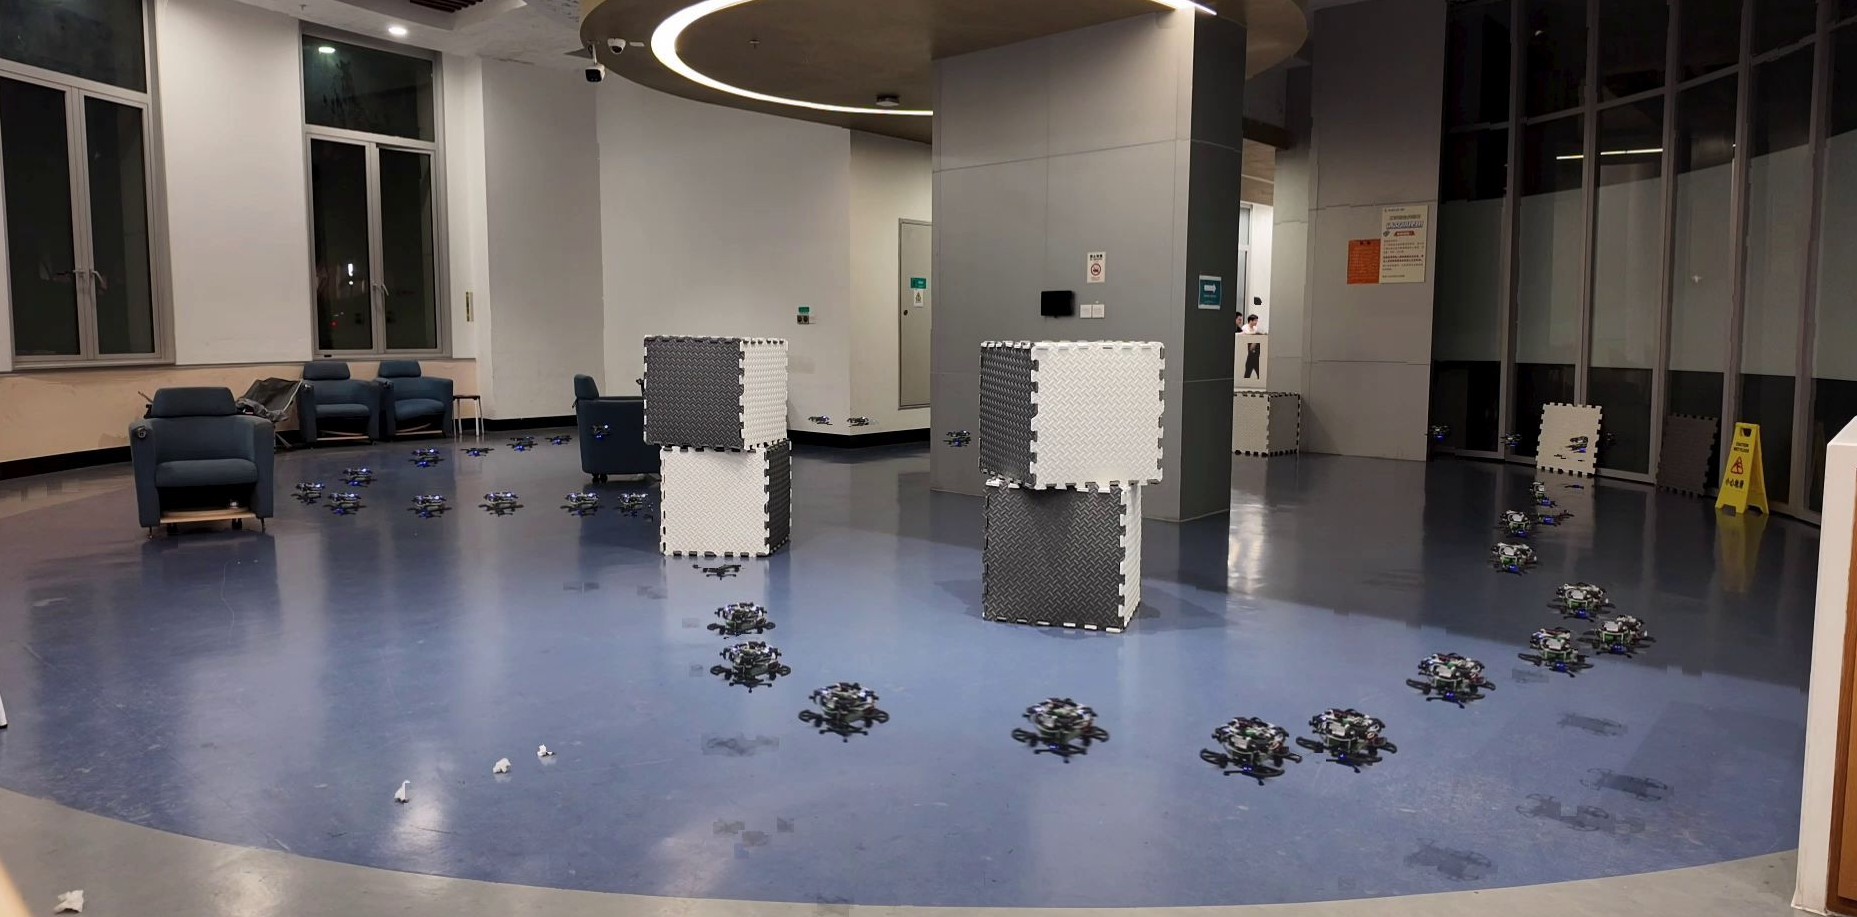
Palm-sized Omnidirectional Vision-Based UAV Exploration with Sparse Topological Map Guidance, Under Review, 2026 [video] [preprint]
Zirui Wang*, Xinjia Luo*, Haotian Sun, Jun Ma, Jian Guo, and Boyu Zhou
- A UAV exploration framework using a palm-sized UAV with omnidirectional visual input.
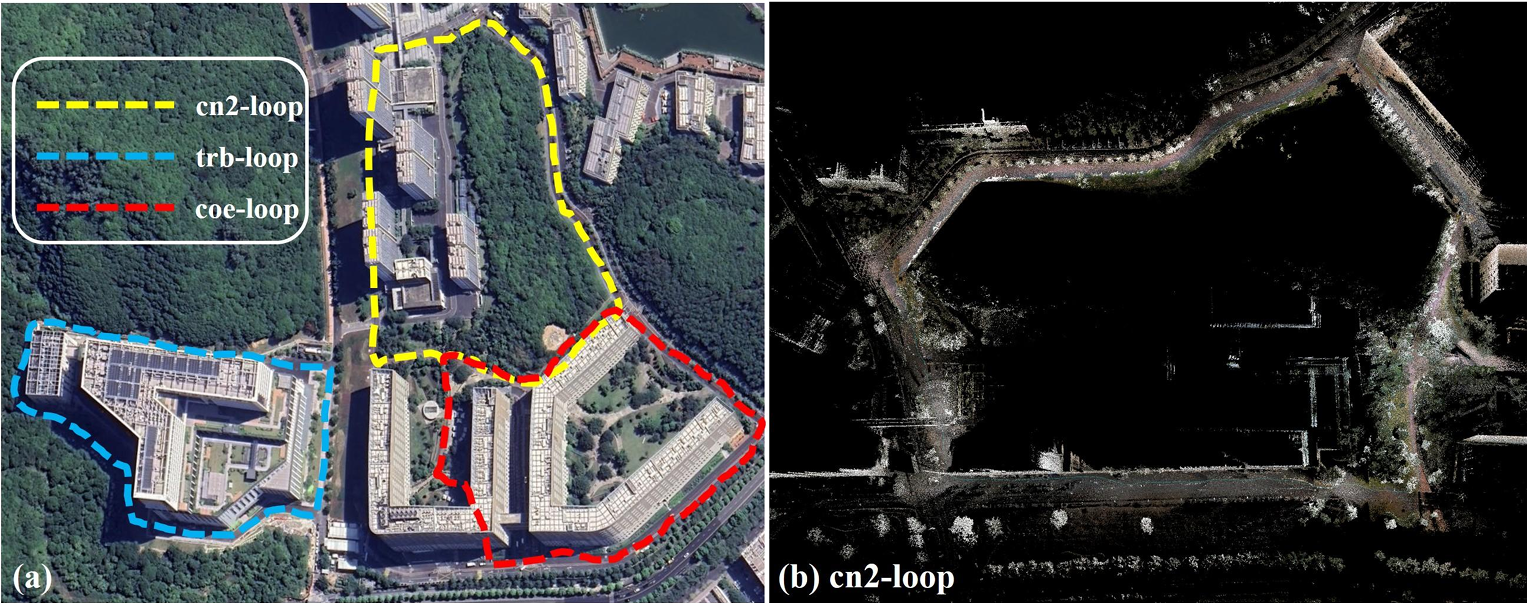
FAST-LIEO2: Fast and Tightly-coupled LiDAR-Inertial-Event Odometry, IEEE Robotics and Automation Letters, 2026 [website]
Jiang Wu, Zirui Wang, Jing Wu, I-Ming Chen, Zhenzhong Jia, and Boyu Zhou
- We propose FAST-LIEO2, an upgraded version of FAST-LIEO, with improved estimation accuracy and robustness across diverse structural and illumination conditions.

FAST-LIEO: Fast and Real-time LiDAR-Inertial-Event-Visual Odometry, IEEE Robotics and Automation Letters, 2025 [paper] [website]
Zirui Wang, Yangtao Ge, Kewei Dong, I-Ming Chen, Jing Wu
- In this paper we propose FAST-LIEO, a novel LiDAR-inertial-event-visual odometry. Our system supports both LIEO and LIEVO that can tightly fuse LiDAR, IMU, event camera (and standard RGB camera) measurements.

Are We Ready for Planetary Exploration Robots? The TAIL-Plus Dataset for SLAM in Granular Environments, ICRA 2024 Workshop on Field Robotics [pdf] [website]
Zirui Wang*, Chen Yao*, Yangtao Ge*, Guowei Shi*, Ningbo Yang, Zheng Zhu, Kewei Dong, Hexiang Wei, Zhenzhong Jia, Jing Wu
- We release the TAIL-Plus dataset, an extension to TAIL dataset for SLAM in planetary surface analog environments.

TAIL: A Terrain-Aware Multi-Modal SLAM Dataset for Robot Locomotion in Deformable Granular Environments, IEEE Robotics and Automation Letters, 2024 [preprint] [website]
Chen Yao*, Yangtao Ge*, Guowei Shi*, Zirui Wang*, Ningbo Yang, Zheng Zhu, Hexiang Wei, Yuntian Zhao, Jing Wu, Zhenzhong Jia
- This paper presents TAIL (Terrain-Aware multI modaL) dataset, targeting the development of mulit-sensor fusion SLAM for robots in deformable granular scenes.
Automatic Extrinsic Calibration for Structured Light Camera and Repetive LiDARs, Yangtao Ge, Chen Yao, Zirui Wang, Haoran Kang, Wentao Zhang and Jing Wu, ROBOTICA, 2024 [pdf]
Semantic Mapping based on Visual SLAM with Object Model Replacement Visualization for Cleaning Robot, Zirui Wang, Haiou Liao, Zhenzhong Jia, Jing Wu, ROBIO 2022 [pdf]
🏢 Teaching
- 2023 Spring, ME5115 Autonomous Robotic Systems, Teaching Assistant
- 2026 Summer, Red Bird Challenge Camp, Teaching Assistant
📖 Educations
- 2025.09 - Present, Ph.D, The Hong Kong University of Science and Technology (Guangzhou)
- 2022.09 - 2025.06, Master of Science, Southern University of Science and Technology
- 2018.09 - 2022.06, Bachelor of Science, Southern University of Science and Technology
💻 Experience
- 2021, Rapidamic-SUSTech Undergrad Engineer Research and Innovation Summer School
- Research topic: gesture control based on sEMG
- 2020, CI-LAM (China-Italy Laboratory on Advanced Manufacturing) Summer School (remote)
- 2019, RoboMaster University Championship
🎮 Others
- …
- …